
Robotics - Yaskawa
Robotics is a rapidly growing field in industrial settings, and there is an increasing demand for Robotics products and solutions in manufacturing settings. Industrial Robotics is the application of robots in an in...
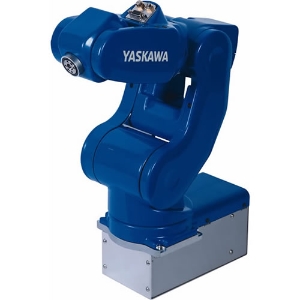
Servo accessories enhance the functionality, precision, and integration of servo motor systems, supporting optimal motion control in automation, robotics, and CNC applications. These components include encoder cables, mounting brackets, gearboxes, couplings, and connectors, each designed to improve connectivity, simplify installation, and ensure accurate, reliable performance.
Industrial robots are programmable, automated machines designed to handle repetitive or complex tasks with precision and speed in manufacturing and production settings. They can weld, assemble, paint, pick and place items, or inspect products, all with consistent quality and minimal human error. Used in industries like automotive, electronics, metalworking, and packaging, industrial robots improve efficiency, reduce labor costs, and enhance workplace safety by taking on dangerous or demanding jobs. Their flexibility and reliability make them essential tools for modern factories aiming to boost productivity and maintain high standards of quality.
$20,515.77$45,428.57
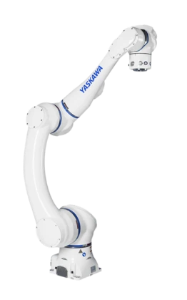
$48,773.34$51,666.67
$20,515.77$45,428.57
$48,773.34$51,666.67
- Industrial robots are categorized by their mechanical structure and range of motion. Articulated robots (the most common type) have rotary joints — typically six axes — providing maximum flexibility and reach, suited for welding, painting, assembly, material handling, and machine tending. SCARA robots (Selective Compliance Articulated Robot Arm) have four axes optimized for fast, precise horizontal motion, making them ideal for pick-and-place, assembly, and packaging. Delta (parallel) robots use three or four overhead arms for extremely high-speed picking of small, lightweight items — common in food packaging and pharmaceutical sorting. Cartesian/gantry robots move along linear axes (X, Y, Z) and are used for large-area material handling, palletizing, and CNC-style operations. Collaborative robots (cobots) are designed to work safely alongside humans without fencing.
- A collaborative robot is designed with built-in safety features — force/torque sensing, speed monitoring, rounded geometries, and power limiting — that allow it to operate in direct proximity to human workers without requiring safety fencing. Cobots meet ISO 10218 and ISO/TS 15066 standards for human-robot collaboration. They are best suited for applications where human-robot interaction adds value: machine tending (loading/unloading parts while an operator oversees quality), light assembly and kitting, quality inspection, palletizing at moderate speeds, and tasks that are ergonomically difficult for humans (repetitive lifting, awkward positioning). Cobots are also significantly easier to program than traditional robots — many can be taught by physically guiding the arm through the desired path. They are ideal for small-to-medium manufacturers with high-mix, low-volume production where flexibility and fast changeover matter more than maximum speed.
- A good candidate for robotic automation typically involves tasks that are repetitive, consistent, and well-defined — the robot performs the same motion pattern reliably, cycle after cycle. Key evaluation criteria include cycle time (can a robot meet or exceed the required throughput?), part consistency (are parts presented in a known position and orientation, or is vision-guided picking needed?), payload and reach (does the part weight and work envelope fall within available robot specifications?), and return on investment (does labor savings, quality improvement, or throughput increase justify the capital cost within an acceptable timeframe?). Applications with high labor turnover, ergonomic risks, quality consistency requirements, or 24/7 production schedules are especially strong candidates. Start with a process assessment that maps the current manual workflow, identifies bottlenecks, and calculates the projected ROI.
- Robot programming defines the motion paths, speeds, logic, and I/O interactions that the robot executes during operation. Traditional programming uses a teach pendant — a handheld device connected to the robot controller — where the programmer manually jogs the robot to each waypoint and records the position. This method is effective but time-consuming for complex paths. Offline programming (OLP) uses PC-based software to create and simulate robot programs in a 3D virtual environment before downloading to the real robot, reducing production downtime. Collaborative robots have introduced hand-guiding (lead-through teaching), where the operator physically moves the robot arm through the desired path and the robot records the motion — no coding required. The newest generation of software platforms use intuitive graphical interfaces, drag-and-drop logic, and even AI-assisted path planning to make robot programming accessible to non-specialists.
- The work cell layout determines the robot's effectiveness, safety, and accessibility for maintenance. Key considerations include robot reach and work envelope (ensure all pick, place, and process points fall within the robot's reach without overextension), floor space and mounting (floor, ceiling, wall, or pedestal mounting affects reach geometry and footprint), part presentation (infeed conveyors, fixtures, or vision-guided bin picking must reliably present parts within the robot's access), end-of-arm tooling clearance (verify the EOAT does not collide with fixtures, conveyors, or the robot itself throughout the motion path), safety zone design (safety fencing, light curtains, or area scanners must protect personnel access points per the risk assessment), and utility access (power, air, network cabling, and control panel placement for easy access and maintenance). Use robot simulation software to validate the layout, check reach, detect collisions, and optimize cycle time before committing to physical installation.